How a Star Polymer Embraces Its Prey ✛
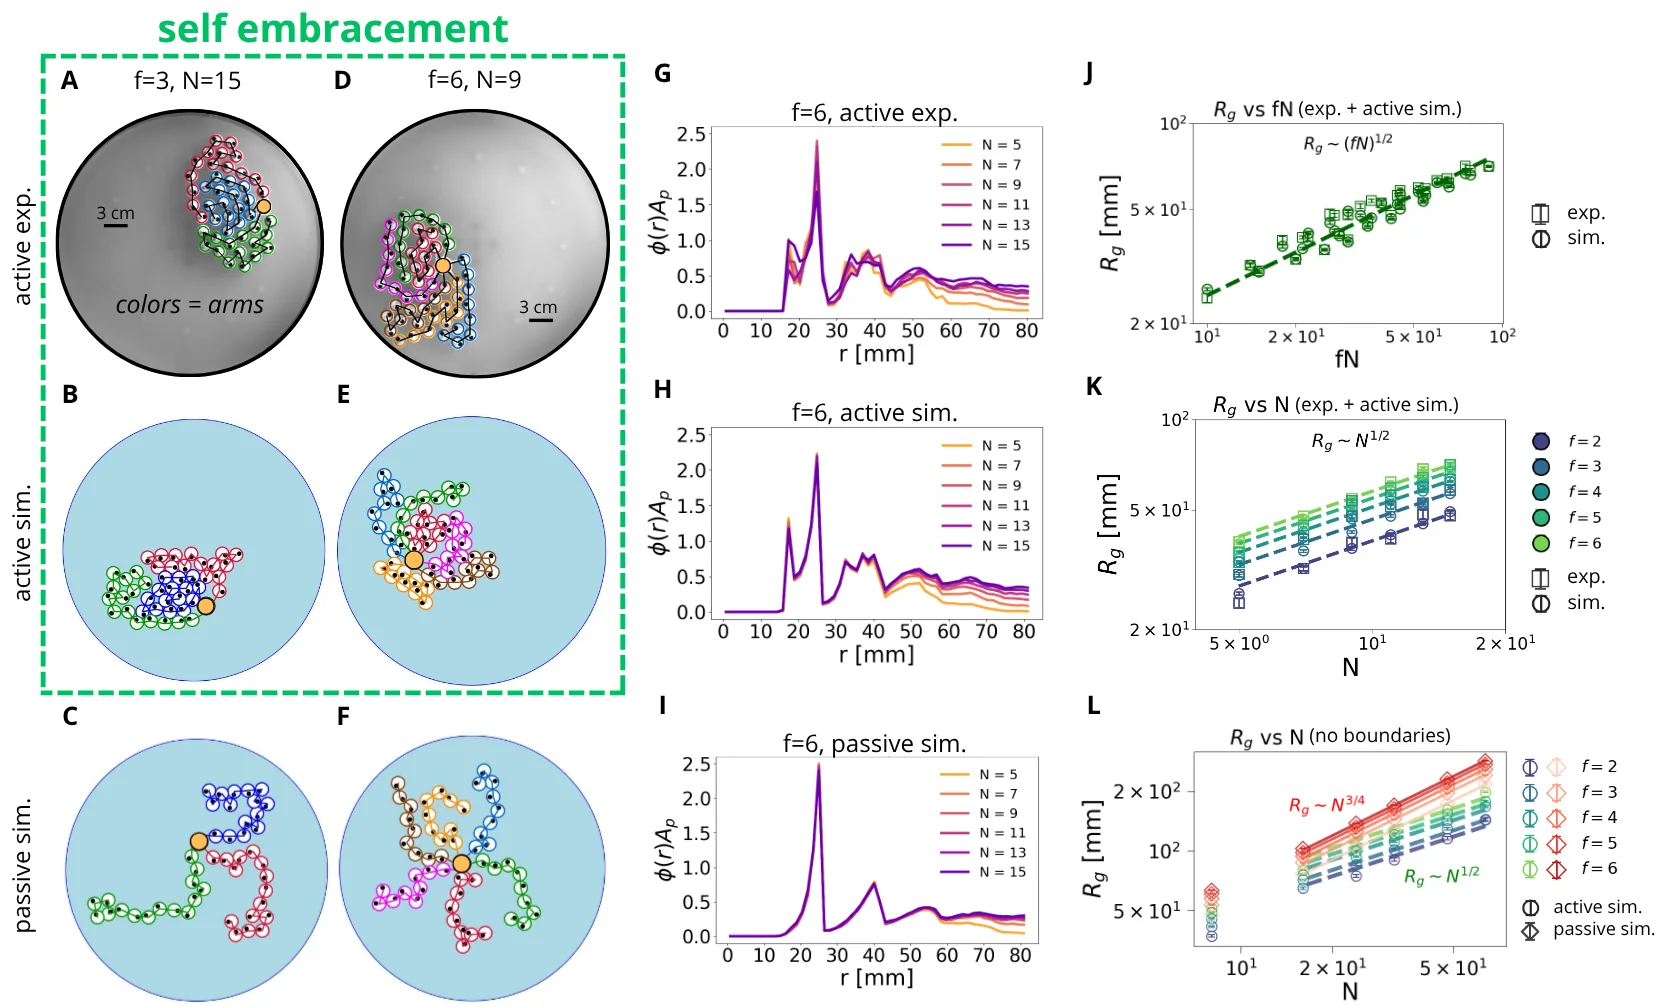
An octopus spreads its tentacles and waits. No one tells each arm what to do, but when prey touches one, all eight wrap around it. The same behavior is seen in a star polymer with self-propelled arms, assembled by physicists from tiny vibrobots.
Each vibrobot is a small cylinder with slanted legs that crawls across a vibrating plate. They are connected by rigid rods into a star. The arms pull in different directions, but when they collide, they catch on each other due to friction. So the star does not fall apart but folds into a dense ball and embraces whatever is nearby.
Previously, it was unclear whether such a structure could be made to grab objects purposefully. It turns out it can: self-propulsion plus friction gives an active embrace. This principle can already be used for soft robots that grab and carry loads on their own, and in the future, for tiny delivery systems.
Active star polymers capture passive particles like a spider wrapping its prey in its legs, even though they have neither a nervous system nor sensors.
The behavior of active star polymers resembles soft robotic manipulators from science fiction, such as Doctor Octopus's tentacles in the Spider-Man universe, which autonomously grasp objects.