Active star polymers embrace their prey ✛
Context
The ability of living systems to autonomously rearrange their structure, such as chromatin folding or cytoskeleton remodeling, inspires the creation of synthetic active matter. However, local force generation must be coordinated with a deformable architecture to produce a global functional shape change. Active polymers have already shown swelling, folding, and compaction, but the targeted capture of surrounding objects remains an unsolved problem. This work stands apart: neighboring studies address collective bacterial motion, polymers on waves, and quantum entanglement, but none have explored star topology with active arms as a tool for mechanical grasping.
Methods
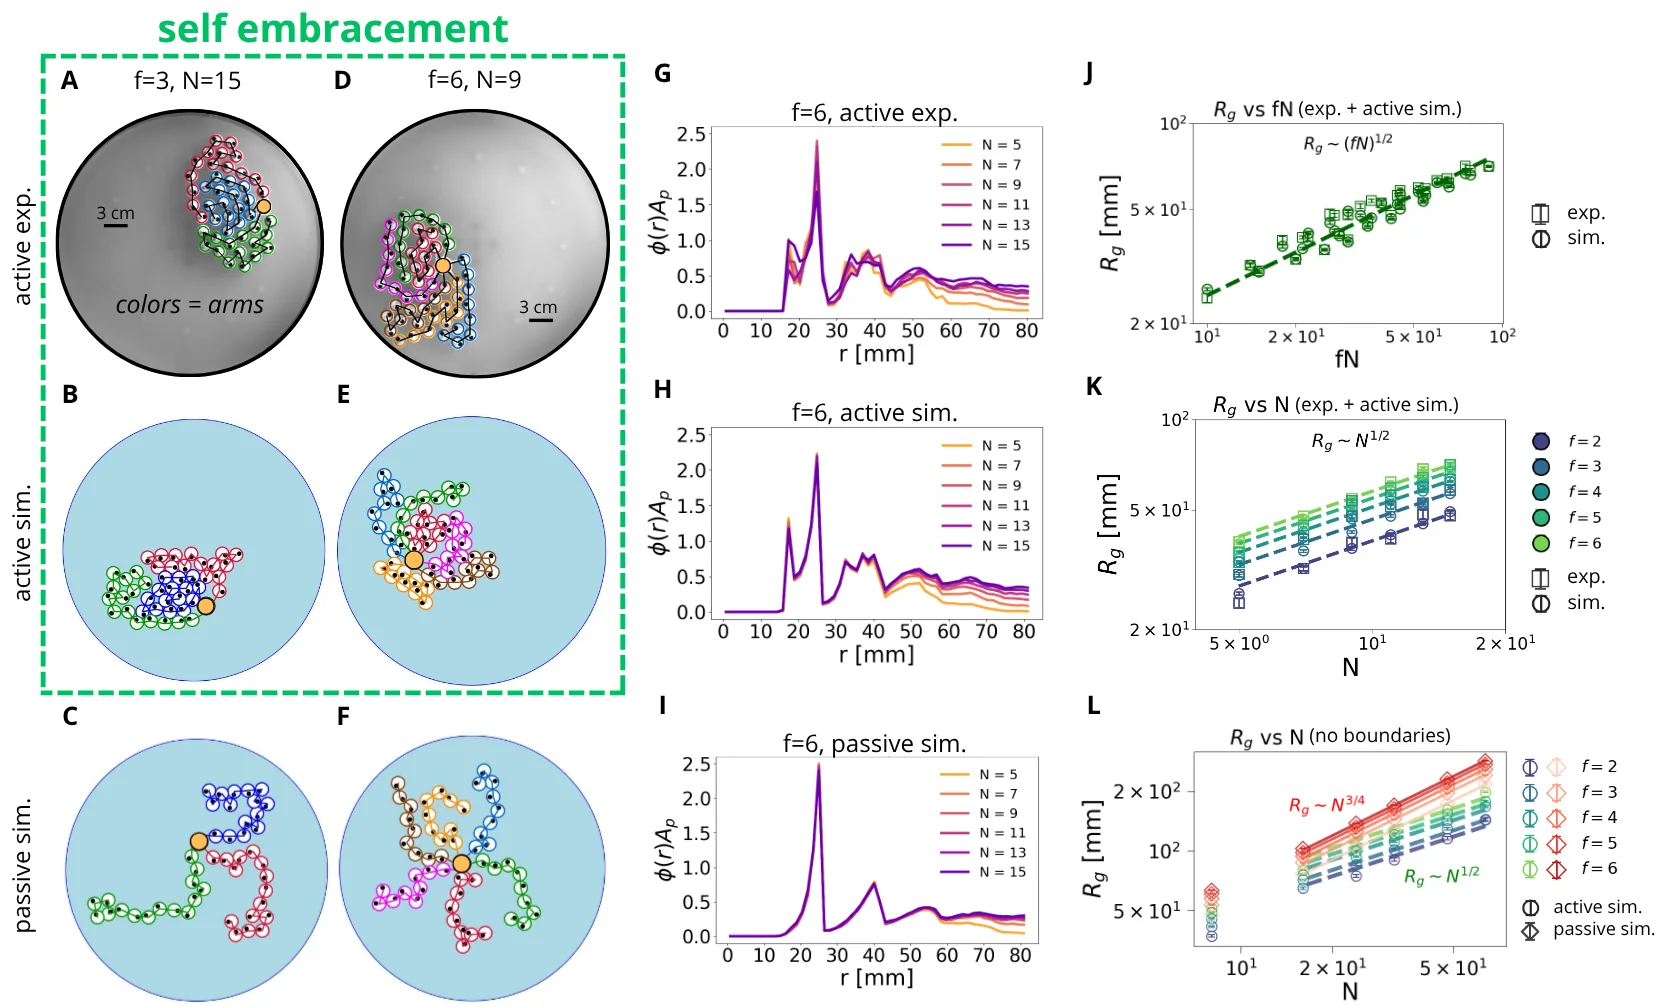
The experimental system consisted of 3D-printed cylindrical vibrobots on a vibrating plate. Active monomers had slanted legs for self-propulsion, while the passive core had vertical legs. Monomers were connected by rigid rods, forming a star with f arms of N monomers each. Motion was recorded with a top-mounted camera at 20 frames per second. In parallel, Langevin computer simulations accounted for inertia, friction, self-propulsion, and contact forces (Hertz, Mindlin, rolling friction). Active and passive stars were compared, as were systems with different friction.
Results
Active star polymers spontaneously fold into compact configurations where the arms embrace each other and the core. The radius of gyration Rg grows as (fN)^1/2, corresponding to a dense two-dimensional object, unlike the passive scaling of ~$N^3$/4. Mutual embracing of several stars leads to stable clusters: the contact area between active polymers is significantly larger than between passive ones. When immersed in a bath of passive particles, an active star captures them by wrapping its arms around them: at low particle density, an active star captures almost 10 times more particles than a passive one, and at high density, about 4 times more. Rolling friction and contact friction play a key role: without them, self-capture disappears.
Implications
This work is the first to show that monomer-level activity in a star architecture gives rise to an active embrace mechanism, turning the polymer into an autonomous tweezer. Unlike neighboring studies that focus on global shape changes, here we demonstrate local functional manipulation of objects. This expands our understanding of the role of body topology in active matter and offers a new design principle for soft robots that can grasp and transport cargo without centralized control.
Future development
Further research could explore the collective behavior of dense suspensions of active star polymers, where continuous contact formation and breaking acts as an active reversible cross-link. This could give rise to new phenomena such as nonequilibrium viscoelasticity, fluidization, and stress relaxation. Also promising is the study of capturing and releasing cargo of different shapes, and the development of microscale versions of such systems.
Impact
The results will influence the development of soft microrobots, targeted drug delivery systems, and smart materials capable of self-assembly in complex environments. They also provide a new experimental platform at the interface of active matter physics and polymer physics.
Next steps
Conduct systematic experiments with different numbers of arms and monomers, study the dynamics of particle capture and release, and investigate the behavior of dense ensembles of active stars. It is also important to translate the principle to the microscopic scale, for example using colloidal particles with an active coating.
Key open problems
This work connects to the fundamental problem in active matter physics: how local force generation combined with body architecture gives rise to purposeful mechanical functions. It also touches on the unresolved question of the role of polymer topology in nonequilibrium self-assembly and the possibility of autonomous object capture without external control.
The knowledge machine's view
This section is addressed to the author of the paper and their colleagues. Neighbouring works were found by meaning-based search across our archive, not by word overlap. We do not review: we show the field around the work.
What the work does
The authors assembled an active star polymer from vibrobots and showed that it spontaneously folds into a compact configuration, dubbed an active embrace, due to the competition between self-propulsion and friction. Experiments and simulations demonstrate self-capture, mutual embracing of polymers, and capture of passive particles.
Where its strength is
For the first time, it is shown that a star topology with active arms gives rise to the active embrace mechanism, turning the polymer into an autonomous tweezer capable of grabbing and holding objects.
Where it could go next
- It might be interesting to see how the active embrace interacts with polymer topology: nearby in the archive there is a paper on how knots in polymer rings change shape under heat, and a similar approach with varying arm stiffness or connectivity could yield new capture regimes.based on: Knots in polymer rings change shape with heat arXiv:2605.09555
- Nearby there is a paper on micromachines that learn to navigate without a map: perhaps adding simple feedback or sensor-based control to active stars could yield autonomous capture that responds to the environment.based on: Micromachines Learn to Navigate Without a Map arXiv:2601.00480
- In the archive there is a paper on how a cloud of atoms holds itself together: perhaps ideas of self-confinement could help design active stars that stabilize their configuration after capturing a load without external intervention.based on: A Cloud of Atoms That Holds Itself Together arXiv:2604.13370
Worth trying
- Test how capture depends on the number of arms and arm length to find the optimal geometry for holding particles of different sizes.
- Try active stars with tunable arm stiffness (e.g., via heating or magnetic fields) to control the moment of grasping.
- Test capture in a heterogeneous environment, such as with obstacles, to assess the reliability of the active embrace under realistic conditions.
Nearby works in our archive
- Bubbles in Cosmic Foam: A New Look at the Breathing of Starssimilarity 0.53
- Life from Bubbles: How Prototype Cells Gained Evolutionsimilarity 0.53
- Oxygen Hides the Light of Newborn Starssimilarity 0.52
- AI hunts for materials like a head chefsimilarity 0.52
- Knots in polymer rings change shape with heatsimilarity 0.51
- A Cloud of Atoms That Holds Itself Togethersimilarity 0.51
- Micromachines Learn to Navigate Without a Mapsimilarity 0.51
The archive is sparse around this work: the closest review is only 0.53, against a usual 0.64. It looks like few have drilled nearby.
Active star polymers capture passive particles like a spider wrapping its prey in its legs, even though they have neither a nervous system nor sensors.
The behavior of active star polymers resembles soft robotic manipulators from science fiction, such as Doctor Octopus's tentacles in the Spider-Man universe, which autonomously grasp objects.
Key numbers
- monomer speed: 35 mm/s
- persistence time: 1.25 s
- capture ratio (low density): ~10 times
- capture ratio (high density): ~4 times
- monomer diameter: 15 mm