Ancient Greek philosopher Aristotle believed that motion requires a constant force. Only in the 17th century did Galileo Galilei, through thought experiments with inclined planes, show that a body maintains its speed without any effort if there is no friction. Isaac Newton generalized this idea as the first law of mechanics in his work 'Mathematical Principles of Natural Philosophy' (1687). The law states: there exist reference frames (inertial, i.e., moving without acceleration) in which a free body remains at rest or in uniform rectilinear motion until forces compel it to change that state.
History
The idea of inertia matured gradually: Nicolaus Copernicus suggested that the Earth moves without visible effort; Galileo Galilei in his 'Dialogues' (1632) proved that a ball rolling on a perfectly smooth horizontal surface would roll forever. René Descartes in 1644 was the first to formulate the principle of conservation of momentum in a straight line. Isaac Newton in 1687 presented the law in its final form as an axiom of mechanics, the foundation of all classical dynamics.
How it works
The law applies in all inertial reference frames — the condition of zero net force is sufficient. In the presence of forces, inertia manifests as resistance to a change in speed, which is used in vehicle design (seat belts, airbags), in astronautics (calculation of free-flight trajectories), and in technology (centrifuges, gyroscopes). The limit of applicability is the classical approximation: at speeds close to the speed of light, inertia ceases to be linear and requires special relativity.
In practice
In cars, headrests save the neck during a rear impact: the head is thrown backward by inertia, and the support holds it from sudden movement.
Fun fact
In interstellar space, probes like Voyager encounter almost no resistance and literally obey the first law: once launched, they can travel for billions of years at nearly constant speed.
A thrown stone arcs through the air, but a planet around the Sun follows a closed curve. Why an ellipse, and not a circle or a spiral? Kepler's first law provides the answer, but its usual proof requires heavy computation. This work offers a shorter path — through a single simple ratio of velocities.
Newton gave us a world where bodies move in a void and clocks tick the same for everyone. For three centuries, this picture worked flawlessly. But it relies on many invisible props: absolute position, the 'up-down' direction, and a single rhythm of time for the entire universe. We have never measured these directly — only through the relations between objects.
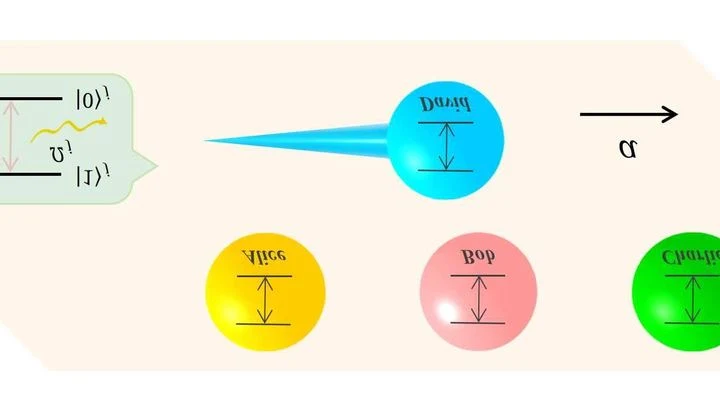
Quantum entanglement is a special connection between particles: they affect each other instantly, even across light-years. For a long time, it was believed that strong acceleration destroys this bond.