Cubes for Catching Neutrinos: How to Reject a Million Parts express
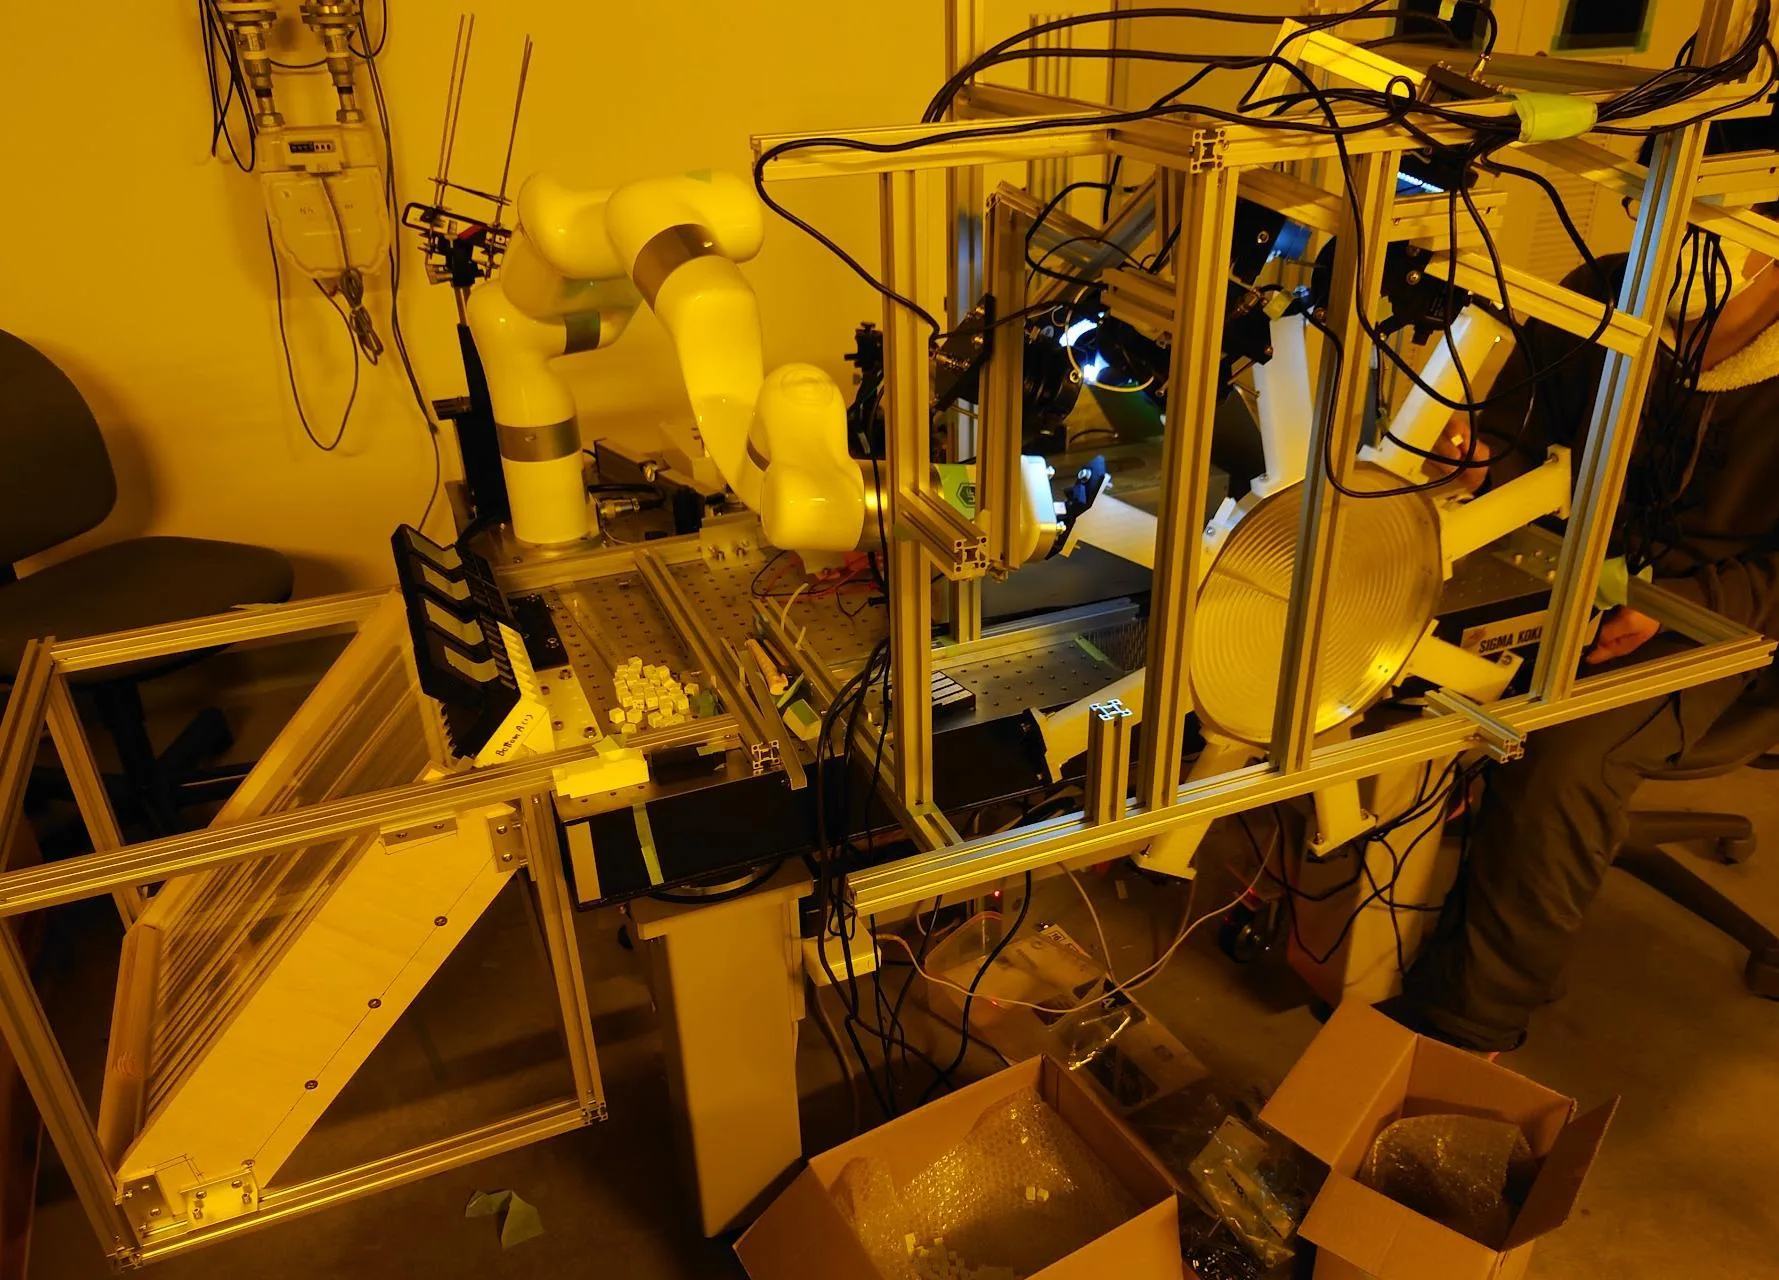
The future neutrino detector will contain millions of tiny plastic cubes: each the size of a die. They flash when a ghostly particle passes through, and that flash must be captured and measured. But if a cube is warped, has a burr, or a hole in the wrong place, the signal gets distorted, and the detector starts lying.
Checking each cube by hand is like sifting through sand on a beach. So engineers built a machine: a rotating stage, six high-resolution cameras, and software that examines the faces. The machine measures the cube's size, surface protrusions, and the position of holes for light guides — thin fibers that collect light from the flash. If any parameter falls outside tolerance, the cube is rejected.
Initially, cubes were simply sorted into "pass" and "fail." But the holes for light guides must sit in place to within fractions of a millimeter, and there are 48 possible orientations. To avoid mixing them up, a six-axis robotic arm was attached: it picks up a cube, turns it to the right side, and places it in its designated bin. In the end, only 3.1% of the batch was rejected — the rest passed inspection.
This assembly line can be scaled to millions of parts. When construction begins on giant neutrino detectors, manual inspection will be impossible, but this system can quickly and accurately sort all the cubes, like a candy-sorting machine, except instead of caramels, it handles particle detectors.
Original abstract
as written by the authors arXiv:2603.26732
Large-scale particle physics detectors often contain millions of repeated components, making precise and efficient quality control essential. We have developed a semiautomatic system for dimensional screening of 1 cm$$^3$$ plastic scintillator cubes for their potential use in future neutrino detectors. The system employs a motorized rotating stage, six high-resolution cameras, and image analysis software to measure cube size, surface protrusions, and the positions of holes for wavelength-shifting fibers used in optical readout. Based on these measurements, each cube is automatically classified as either acceptable or defective. We constructed and validated a prototype system, achieving a measurement precision of 10 $$\mu$$m and over 80% consistency with manual screening. To enable classification of cubes into 48 groups based on hole positions while preserving their orientation, we introduced a 6-axis robotic arm. The completed system achieved a rejection rate of 3.1%. Our approach contributes to scalable, precise, and efficient quality control for future large-scale particle physics detectors.
A plastic scintillator flashes when a charged particle passes through it: this light is what detectors register. A 1 cm³ cube produces a flash lasting only a few nanoseconds.