Light Flows Without Friction: Three Ways to Measure the Limit
In a Paris laboratory, light was made to flow around an obstacle the way water flows around a rock in a stream. But this water is special: it feels no friction.
The classical problem of predicting the motion of three mutually gravitating bodies.The three-body problem is the classic challenge of predicting the future positions and velocities of three objects that interact only through gravity. Unlike the two-body problem, which has a neat, closed-form solution (ellipses, parabolas, or hyperbolas), the three-body problem generally has no such simple formula. Even with perfect knowledge of initial conditions, the motion is often chaotic: tiny differences in starting positions grow exponentially, making long-term prediction impossible in practice.
The problem was first formulated by Isaac Newton in the 1680s, but the term 'three-body problem' and the first serious attempts at solution came from Euler, Lagrange, and others in the 18th century. Henri Poincaré's work in the 1880s–90s showed that the problem is non-integrable and exhibits chaos, a foundational insight for modern dynamical systems theory.
You write down Newton's law of gravitation for each pair of bodies, giving nine coupled second-order differential equations (three for each body's coordinates). For two bodies, you can reduce this to a single equation for relative motion and solve it exactly. For three, no general analytic solution exists. Instead, you must integrate the equations numerically, step by step, and even then, the chaotic nature means that rounding errors in the initial data quickly dominate the solution.
It is used in celestial mechanics for planning spacecraft trajectories (e.g., the Sun–Earth–Moon system), in studying the stability of planetary systems, and in designing orbits around Lagrange points.
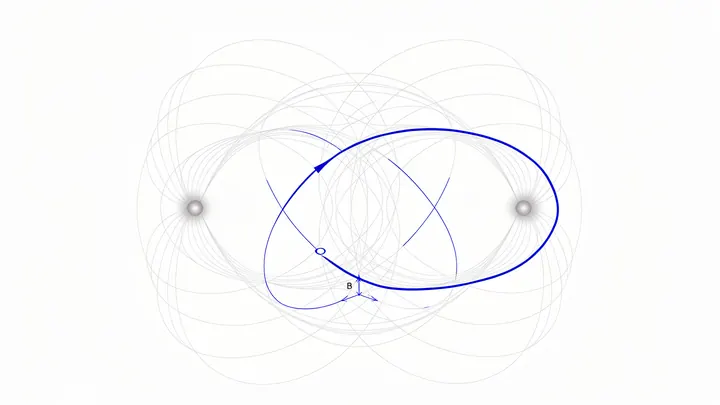
There are a few special solutions, like the figure-eight orbit, where three equal masses chase each other along a single closed path — discovered numerically in 1993 and proven rigorously in 2000.